
Computer vision
Teaching machines to interpret and reason about the visual world, from object recognition to medical imaging.
视频
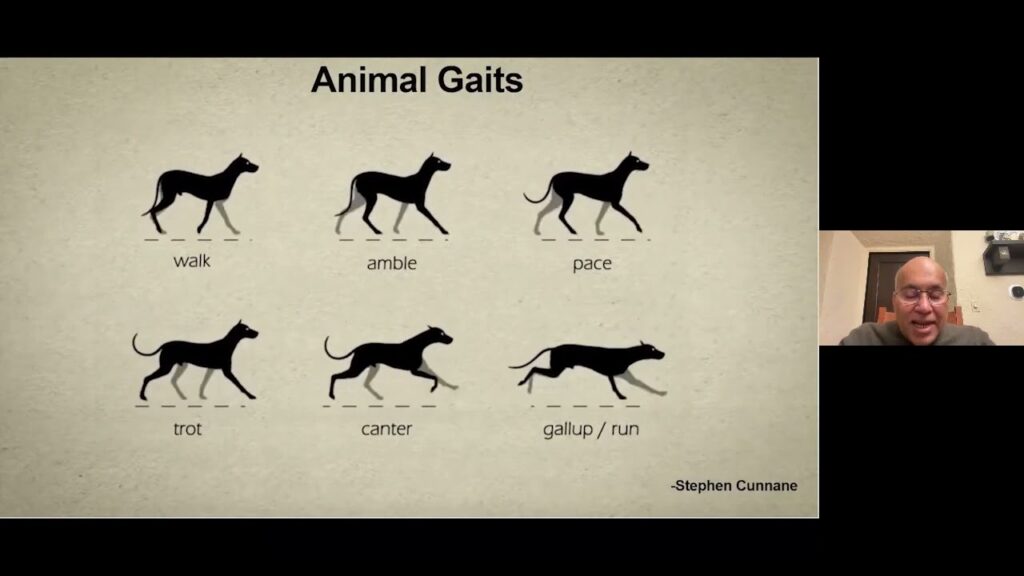
Learning to Walk
Legged locomotion is commonly studied and programmed as a discrete set of structured gait patterns, like walk, trot, gallop. However, studies of children learning to walk (Adolph et al) show that real-world locomotion is often…
项目
Interactive Learning-from-Observation
Service-robot solutions to empower senior citizens to achieve more and to enhance their lives The goal of this project is to develop an interactive learning-from-observation (LfO) system in the service-robot domain so as to…