Artificial Intelligence
Building intelligent machines that complement human reasoning and extend what people can do.
Tool
HoloLens Navigation for Robots
The HoloLens Navigation for Robots project is an open source repository to be included as a release in the Applied Robotics Research Library. It is a set of sample code to build software capable of…
Video
Three Explorations on Pre-Training: an Analysis, an Approach, and an Architecture
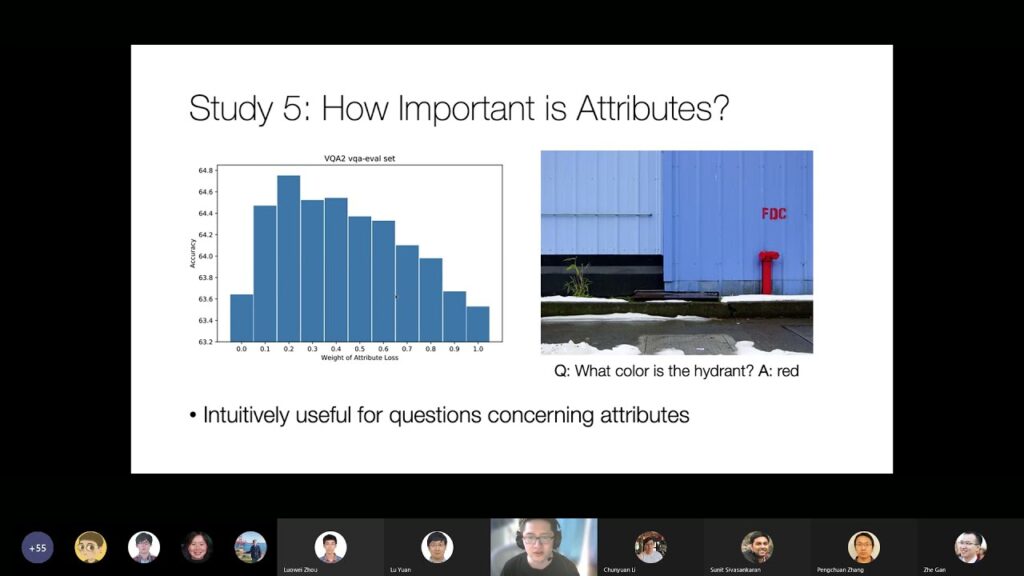
In this talk, I am going to cover three of our recent explorations on pre-training. First is an analysis on object/attribute detection pre-training, which produces bottom-attention features extensively used in vision and language research. The…
Video
Learning Commonsense Understanding through Language and Vision
As humans, we parse language and visual scenes — often together — into a rich understanding of what is going on in the world. Given even a still image or a sentence describing an event,…