
Artificial Intelligence
Building intelligent machines that complement human reasoning and extend what people can do.
Microsoft Research Blog
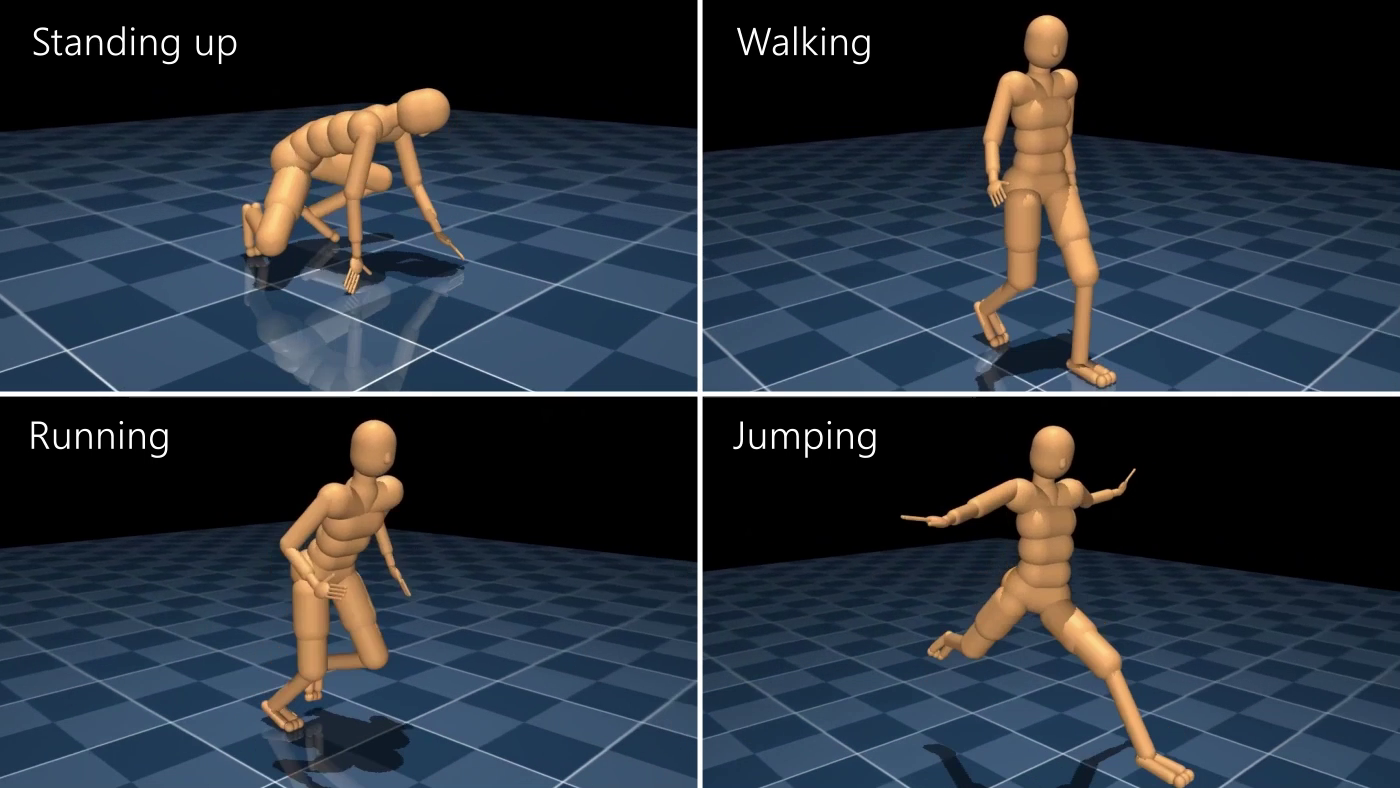
MoCapAct: Training humanoid robots to “Move Like Jagger”
What would it take to get humanoid, bipedal robots to dance like Mick Jagger? Indeed, for something more mundane, what does it take to get them to simply stand still? Sit down? Walk? Move in…
Tool
GODEL
Large-scale pretrained models for goal-directed dialog. This repository showcases building goal-directed dialog using GODEL, and contains the dataset, source code and pre-trained model for the following paper: GODEL: Large-Scale Pre-Training for Goal-Directed Dialog
Video
Microsoft’s AirSim uses virtual world to prepare aircraft for real life challenges
Microsoft’s Project AirSim, a new platform to safely build, train and test autonomous aircraft through high-fidelity simulation, offers developers a “unique” opportunity to use a scalable system that ensures their models can meet real-world challenges,…

Publication
Riemannian Diffusion Models
Publication